The interface
Mechanical fit, electrical connections, sensing and control software must agree. A component is never assessed in isolation.
 ROBOTICSCommission
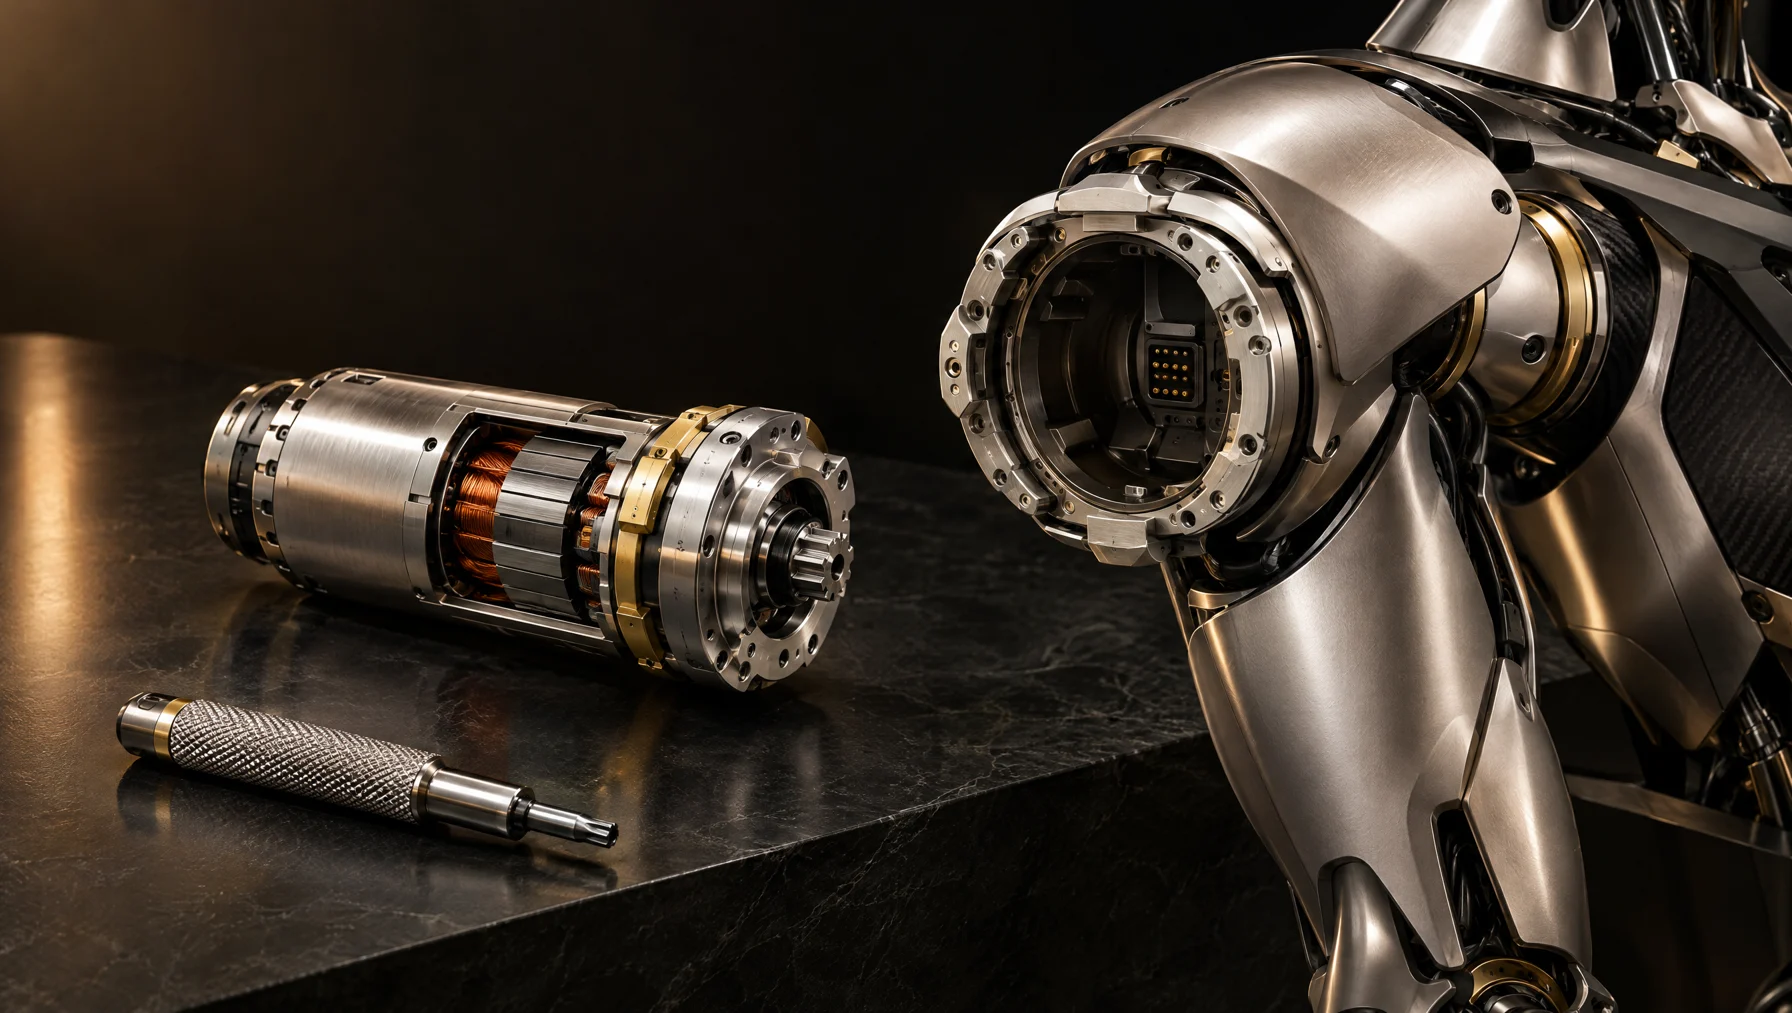
Replaceable actuator concepts, serviceable enclosures and task interfaces connect extraordinary design with long-term ownership.
Commission your robot →Mechanical fit, electrical connections, sensing and control software must agree. A component is never assessed in isolation.
Defined isolation, removal, installation and calibration procedures make qualified servicing repeatable.
Load, temperature, stability and task behavior are evaluated after a configuration change. Universal compatibility is not assumed.
Each direction begins with a platform and feasibility assessment. Images show design concepts; performance and availability are agreed for the specific project.
Replaceable actuators. Serviceable shells.
A system designed around its next chapter.
MODULAR ARCHITECTURE / DESIGN STUDYA proposed removable module brings motor, transmission and encoder into a defined service interface. Torque, thermal behavior and control tuning are evaluated for the chosen platform.
Concept architecture. Compatibility and replacement procedures depend on the selected platform; no autonomous or universal component swap is claimed.
One idea. Your own robot.
Commission