Define
Describe the task, inputs, outputs and handoffs.
 ROBOTICSCommission
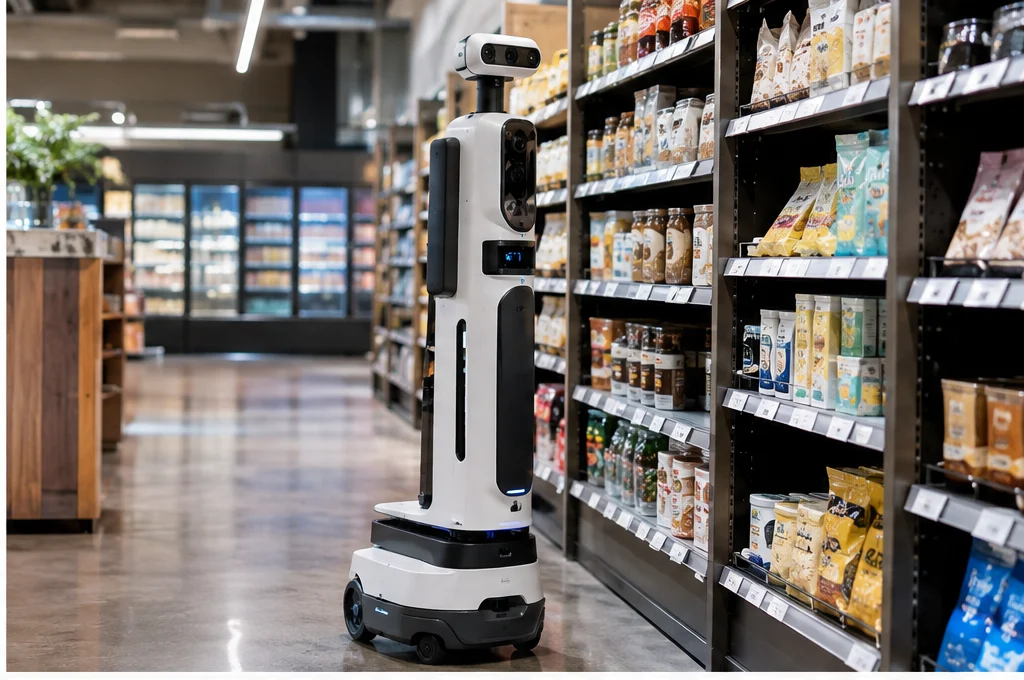
Task profiles connect instructions, site knowledge and approved physical capabilities.
Commission your robot →Describe the task, inputs, outputs and handoffs.
Develop demonstrations, behavior profiles and operator procedures.
Validate the configured task. A stored profile does not create a new physical capability.
Each direction begins with a platform and feasibility assessment. Images show design concepts; performance and availability are agreed for the specific project.
One idea. Your own robot.
Commission